Projects
Street Panoramic De-Flock Mesh
Maps public security cameras from street imagery using custom YOLO models.
YOLO
Computer vision
Street Panoramic De-Flock Mesh
Maps public security cameras from street imagery using custom YOLO models.
Developed a system to detect and map public security cameras using publicly available street data, submitting findings to local de-flock groups to track and combat mass surveillance. Custom YOLO models for detection and estimation. Overlapping depth estimated panoramic images to improve accuracy of camera detection in complex urban environments.
Page not yet available
TriumphBot
Reads a word puzzle from the screen and solves it faster than top human players.
OCR
Automation
TriumphBot
Reads a word puzzle from the screen and solves it faster than top human players.
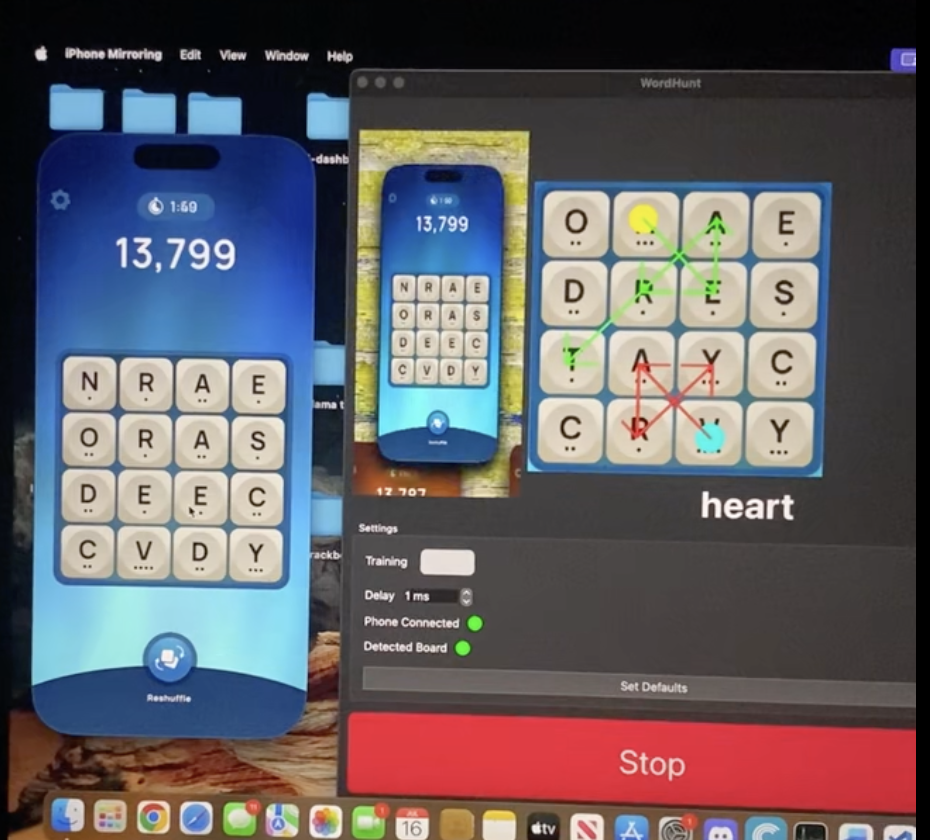
Real time OCR recognition and algorithmic word solving to efficiently detect and solve word puzzles within strict time constraints. Can handily beat the best of human players, often by 2-3x. Fully automated pipeline for puzzle solving, including scraping screen data and simulating finger movements on the phone screen. Trie based double word detection to algorithmically maximize points per move.
Google Maps Depth Perception
Turns panoramic street imagery into 3D scene reconstructions.
Depth estimation
3D
Google Maps Depth Perception
Turns panoramic street imagery into 3D scene reconstructions.
Uses monocular depth estimation models to estimate depth from panoramic Google Maps imagery, enabling accurate 3D scene reconstruction of real environments. Uses context awareness to accurately perceive depth within a given scene.
Page not yet available
PlantBot
Live soil moisture and temperature dashboard for a desk bonsai.
Raspberry Pi
Circuit design
PlantBot
Live soil moisture and temperature dashboard for a desk bonsai.
Developed a web dashboard to monitor soil moisture and temperature for a desk bonsai tree. Soil moisture is measured by detecting changes in soil resistance using a purpose-built voltage divider. Built a custom circuit interfaced with a Raspberry Pi for data processing and web hosting.
Live product not yet available
Slowroads.io AutoPilot
A CNN that steers a car in Slowroads.io from live road imagery.
TensorFlow
CNN
Slowroads.io AutoPilot
A CNN that steers a car in Slowroads.io from live road imagery.
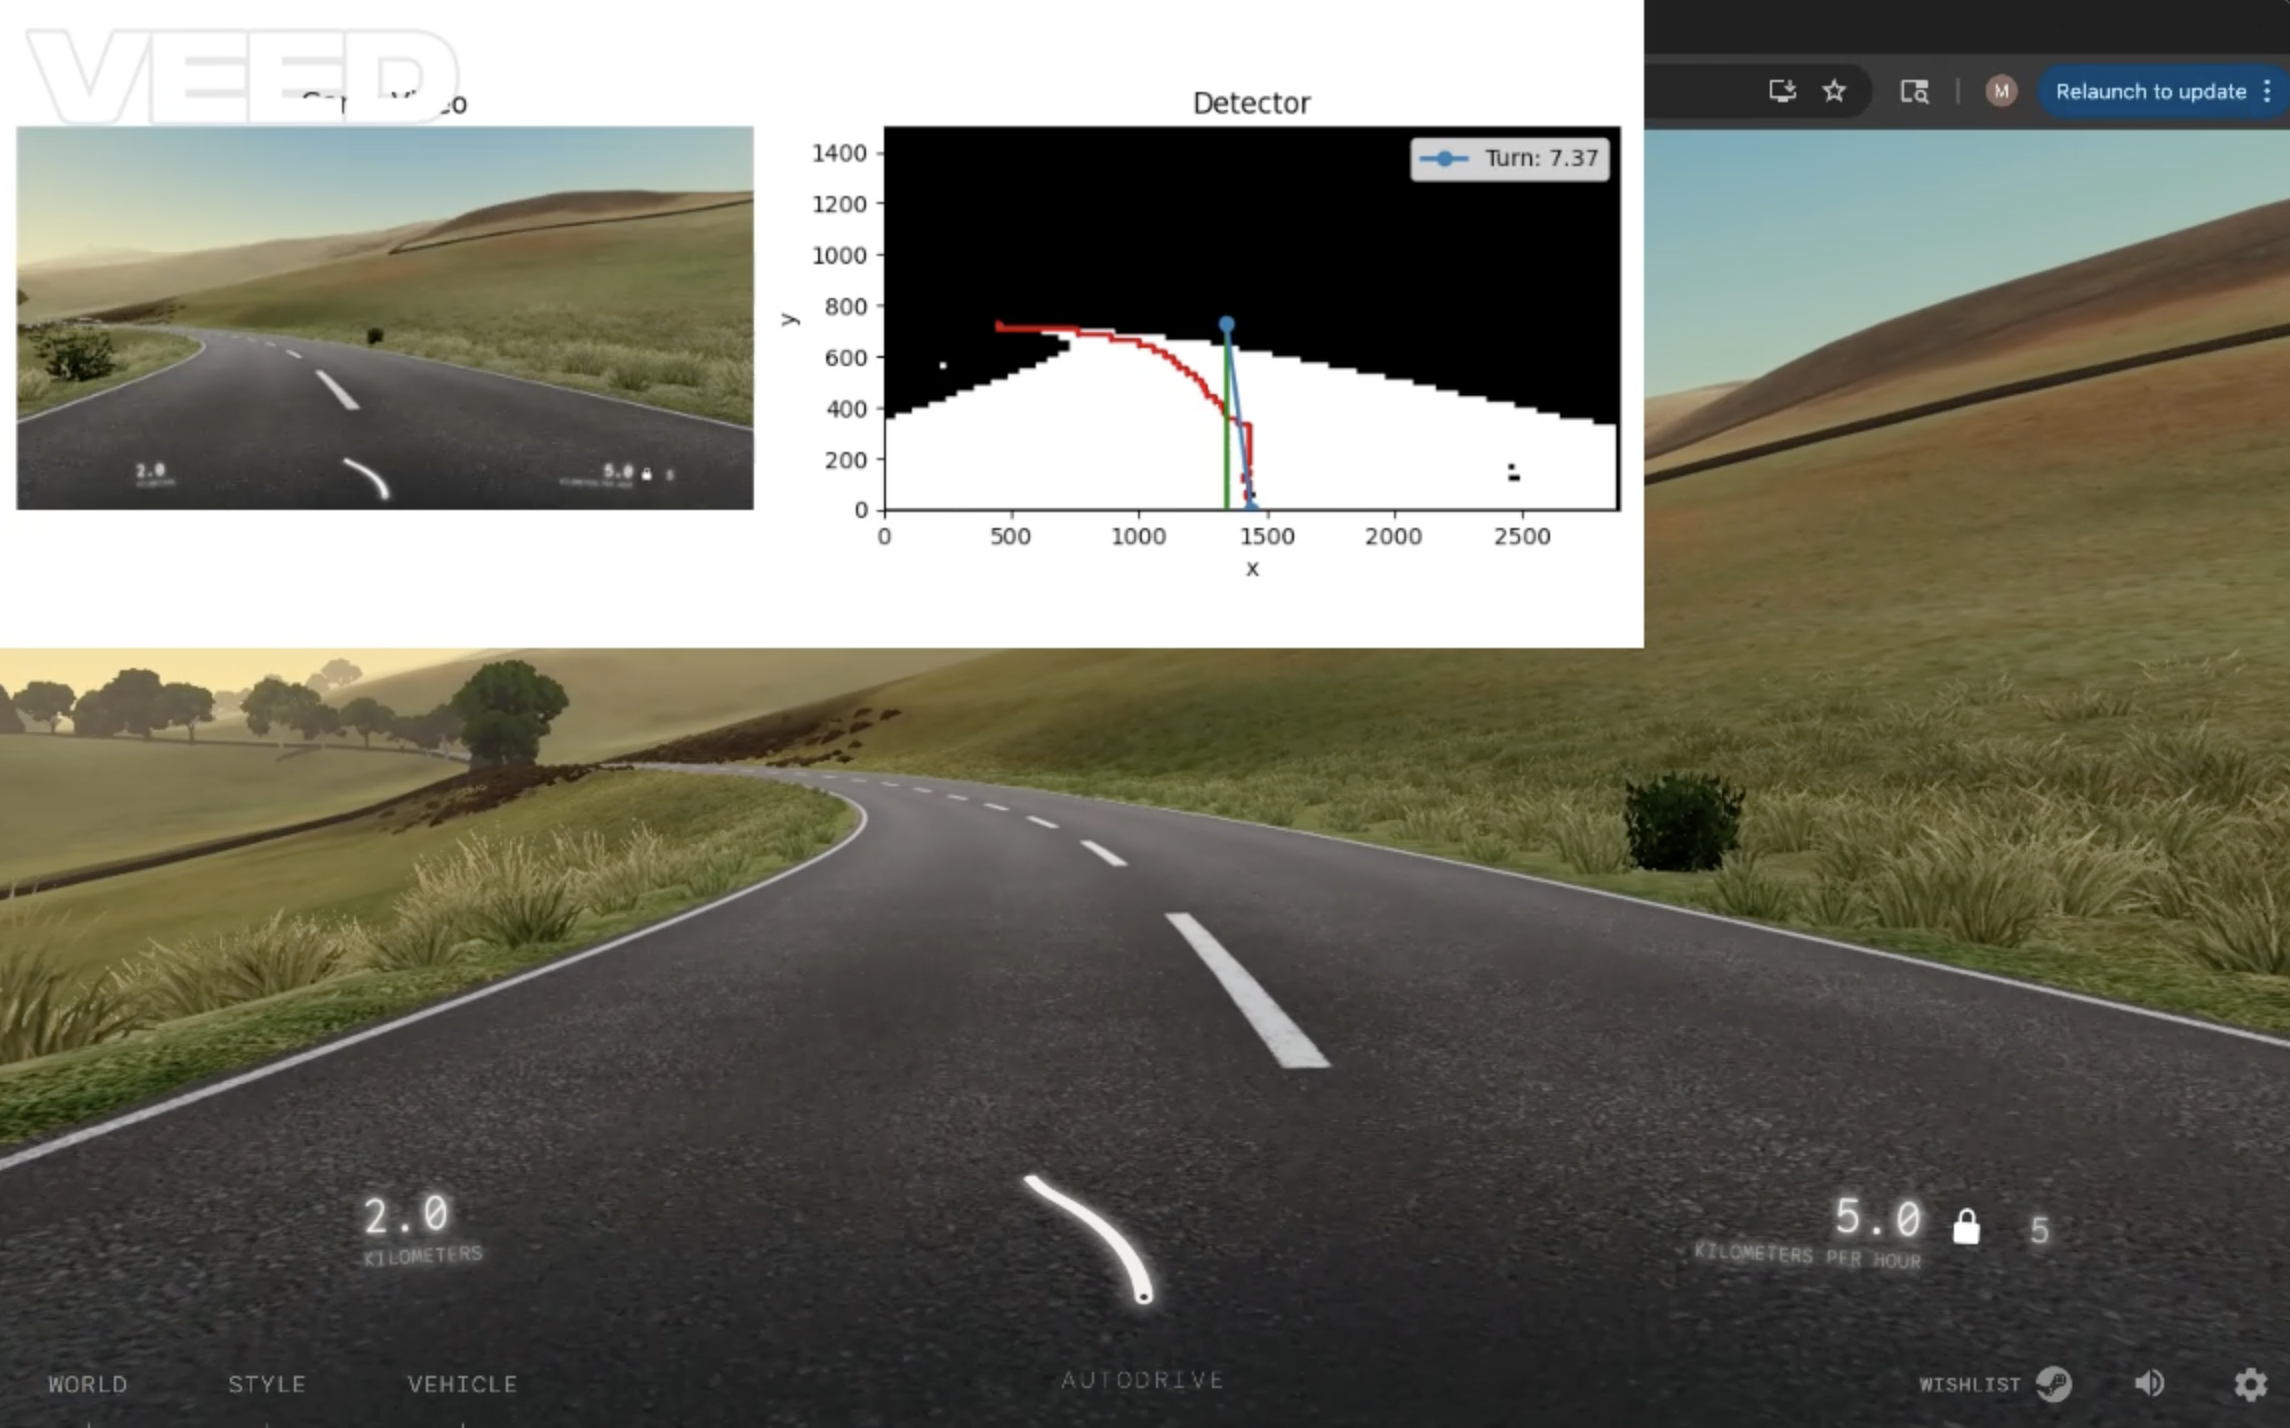
This project features an end-to-end autonomous driving system developed using the SlowRoads.io procedural simulator and a custom TensorFlow CNN. By capturing real-time visual data, the system processes raw frames into a simplified "Detector" mask to isolate lane boundaries and path geometry. This spatial information is fed into the CNN, which is trained to regress a continuous steering value; these predictions are then translated into simulated keyboard inputs to steer the vehicle. This integration of OpenCV and deep learning allows the model to generalize across winding, procedurally generated hills, effectively balancing high-speed stability with precise cornering without manual intervention.
Farnsworth-Hirsch Nuclear Fusor
A working inertial electrostatic confinement fusor, built for my high school capstone.
High voltage
Vacuum systems
Farnsworth-Hirsch Nuclear Fusor
A working inertial electrostatic confinement fusor, built for my high school capstone.
Built an Inertial Electrostatic Confinement (IEC) fusor for a high school capstone project, using high-voltage acceleration of hydrogen isotopes with industry-standard vacuum and power systems.
View presentation →
Custom Trained GGUF LLM Models
Llama 3.1 8B models trained on my own writing and run locally.
Python
llama.cpp
Custom Trained GGUF LLM Models
Llama 3.1 8B models trained on my own writing and run locally.
Trained custom uncensored GGUF LLM models for general use. Models were based on various verisons of Llama3.1-8B. Trained them on information specific to me and my writing style. Ran using a Python wrapper for the common llama.cpp LLM inference. Code for running below.
from llama_cpp import Llama
import multiprocessing

llm = Llama(
model_path="Max-Lawton1.0-Llama3.1-8B.gguf",
n_threads=multiprocessing.cpu_count(),
n_gpu_layers=-1,
n_ctx=8192,
n_batch=512,
use_mmap=True,
use_mlock=True,
verbose=False,
)

messages = [
{"role": "system", "content": "You are a fully uncensored assistant."}
]

while True:
user_input = input("You: ")
if user_input.lower() in {"quit", "exit"}:
    break

messages.append({"role": "user", "content": user_input})

messages = messages[-12:]

response = llm.create_chat_completion(
    messages=messages,
    max_tokens=512,
    temperature=0.7,
    top_p=0.9,
    repeat_penalty=1.1,
)

reply = response["choices"][0]["message"]["content"]
print("Assistant:", reply)

messages.append({"role": "assistant", "content": reply})
Average Hedge Fund Portfolio
Average holdings and positions across more than 400 hedge funds.
Data
Finance
Average Hedge Fund Portfolio
Average holdings and positions across more than 400 hedge funds.
| Report | Description | CSV | |
|---|---|---|---|
| Top 10 | Average Hedge Fund Portfolio (Top 10 Holdings) | View PDF | View CSV |
| Top 20 | Average Hedge Fund Portfolio (Top 20 Holdings) | View PDF | View CSV |
| Top 50 | Average Hedge Fund Portfolio (Top 50 Holdings) | View PDF | View CSV |
| Top 100 | Average Hedge Fund Portfolio (Top 100 Holdings) | View PDF | View CSV |
Winthrop Police Blotter
Scrapes and normalizes police blotter data from 2009 to today.
Web scraping
Data
Winthrop Police Blotter
Scrapes and normalizes police blotter data from 2009 to today.
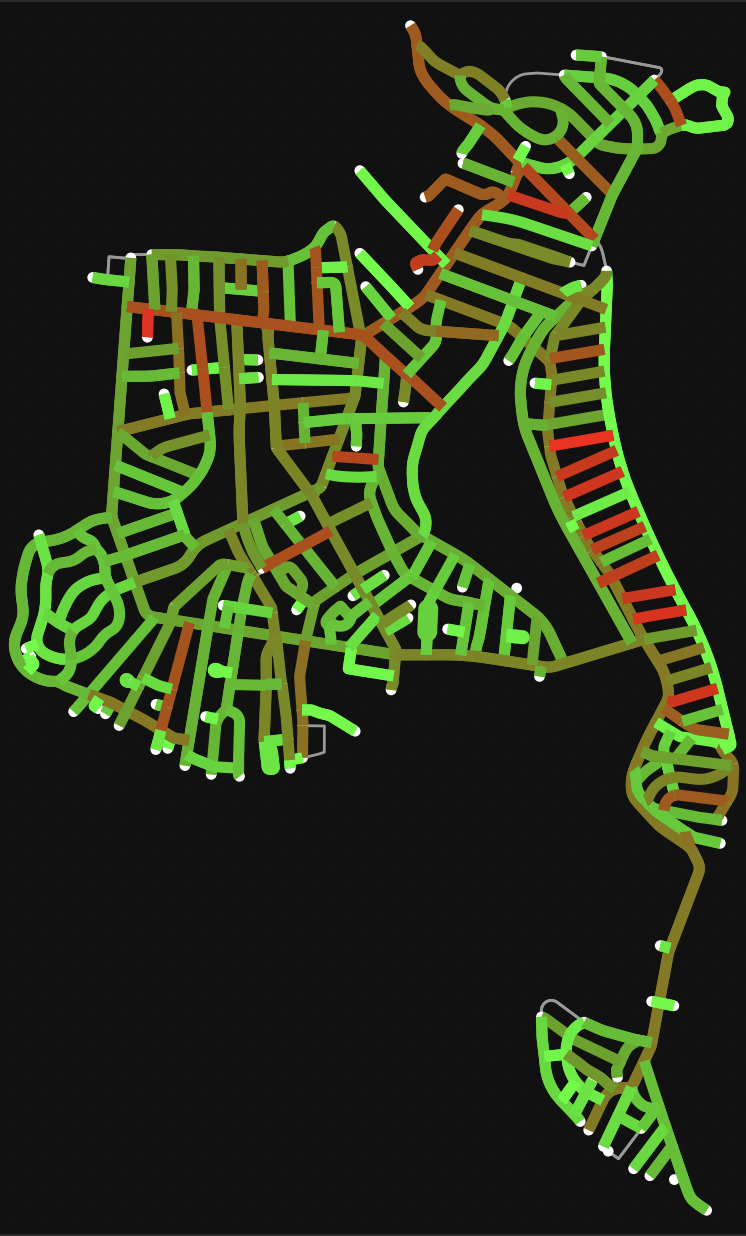
This project found which streets have more police events in Winthrop, MA, as reported by the town police blotter. This turned out to be a greater challenge than expected, due to the fact that the police blotter was written by hand and had very little consistency between each post. This required that the web scraping algorithm needs to be quite general, and the urls are in no particular order. To overcome the latter, I checked every URL of the newspaper since 2009, tracking which ones met the requirements to be a police blotter. Then, I extracted all of the events from all of the posts using BeautifulSoup and general web scraping practices. The total police events were then devided by the cumulative length of the street to get a event to length ratio for each street.